1Introduction
Square Tracker Xtreme tells you where your assets are, indoors and outdoors. Outdoors it uses GNSS (GPS and BeiDou); indoors it scans the Wi-Fi access points around it. It scans when the asset starts or stops moving and at set intervals, and a cloud service turns the scans into positions. Its accelerometer detects motion, and it gives an indication of the temperature. The sealed, grey housing is IP68 and IK06, 67.2 × 60.4 × 13 mm, with a conformal-coated circuit board, for wet, dusty and knocked-about places.
The battery is built in (4,000 mAh) and lasts 10 years at 72 positions a day.
It works with any LoRaWAN network server (LoRaWAN 1.0.4, class A, OTAA) and reaches up to 10 km in line of sight. What it measures, when it reports and what it sends is decided by an application running inside the sensor, on Sensative’s Virtual Sensing Machine (VSM). This manual describes the application Tracker R27–R33, which can be configured, and replaced by a newer version, over the air or with NFC. Sensative can also offer alternative VSM applications for the same sensor, which give it a different task; see Which application is in the sensor.
What’s in the box
- Square Tracker Xtreme, with the adhesive already on the back
- The screw mounting frame
The keys (DevEUI and AppKey) come with the delivery information. Screws and cable ties are not included.
Parts of the sensor
2Before you start
A LoRaWAN sensor needs a little more preparation than a sensor that pairs with a hub. Have this ready first:
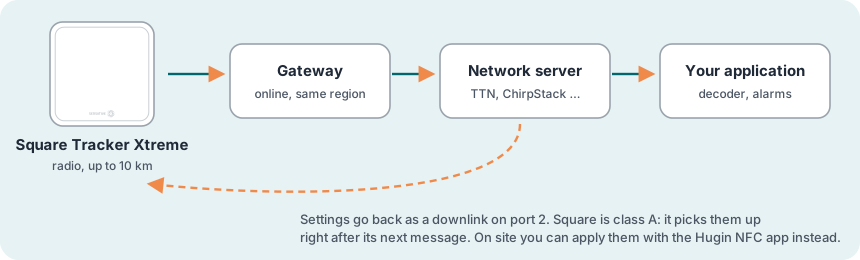
You need
- A LoRaWAN gateway within range, powered on and online
- An account on a LoRaWAN network server (for example The Things Network, ChirpStack, Loriot or Actility), with the gateway added to it
- The keys for the sensor: its DevEUI and AppKey, from the delivery information. The JoinEUI is the same for all Square sensors:
70B3D52C0001D4C3. - A phone with NFC, to start the sensor. Most smartphones have it; an iPhone needs an NFC reading app (see Finding the NFC antennas).
- A payload decoder for Sensative VSM sensors in your network server or application (see Decoding the messages)
- A cloud service that supports GNSS and Wi-Fi positioning, for example Yggio. Without it the scans arrive, but give no position (see GNSS positioning and How Wi-Fi positioning works).
Choosing the place
- On the asset: fix the tracker where it moves with the asset
- Sky view for GNSS: outdoors, GNSS needs an unobstructed view of the sky. Mount the tracker with the front, top or right side towards the sky, with nothing over it: a roof, a cover or the asset itself blocks the signal. GNSS does not work indoors or under a sheltering roof
- Wi-Fi indoors: indoors the position comes from the 2.4 GHz Wi-Fi access points around the tracker (see How Wi-Fi positioning works)
- Outdoors and in vehicles: the housing is IP68 and IK06, for rain, dust and knocks
- Range: up to 10 km in open line of sight, much less through walls and floors
Finding the NFC antennas
NFC only reaches a couple of centimetres, so lay the phone flat against the sensor, antenna over antenna. You need to know where both antennas are, and the easiest way to find the spot is to move the phone slowly over the right area until the phone signals contact:
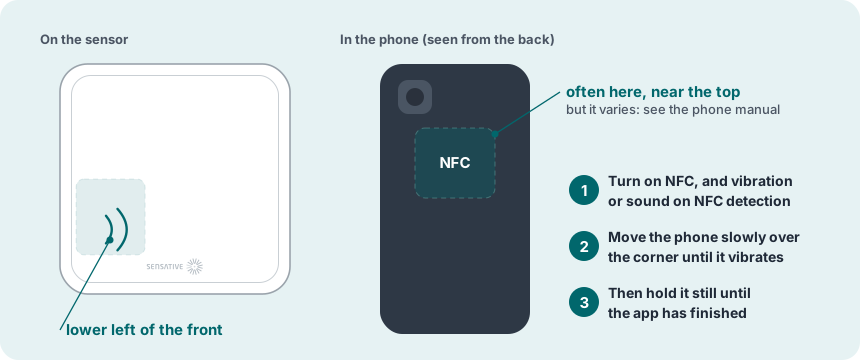
- On the sensor: at the lower left of the front, with the logo along the bottom edge.
- On an Android phone (recommended): switch NFC on, and turn on vibration or a sound for NFC in the phone’s settings, so that the phone tells you as soon as it has found the sensor. The antenna is usually on the back, near the top, often close to the camera, but it varies between models: the phone’s manual or the maker’s website shows where it is. If you cannot find it, move the back of the phone slowly over the sensor’s lower left corner until the phone vibrates.
- Take off the phone case: a protective case, especially a thick one or one with metal or a magnet, can make it hard to get NFC contact. Remove it while you work with the sensor.
- Then hold it still: to start a join, keep the phone still over the sensor for about 5 seconds. The vibration only means the phone has found the sensor. Keep the phone where it is until the sensor and the app have finished talking. With the Hugin app this takes a few seconds, because the app first unlocks the sensor through Sensative’s server. If you move away too early, the connection breaks and you have to start again.
- On an iPhone: use an NFC reading app, such as NFC Reader & Scanner from the App Store. Open it and tap its NFC button, so that it shows Ready to Scan, before you touch the sensor. The iPhone’s antenna is at the top edge of the back. Hold that edge against the sensor’s lower left corner and keep it still; when the read succeeds, a web link with the sensor’s serial number opens. The iPhone NFC join guide (PDF) shows each step with pictures.
3Step by step: from box to ready
8 steps. Register the sensor in the network server before you hold the phone to it. Then join it, check the settings, and mount it last.
Unpack
Check the sensor and find its keys. The sensor sleeps until it meets an NFC field.
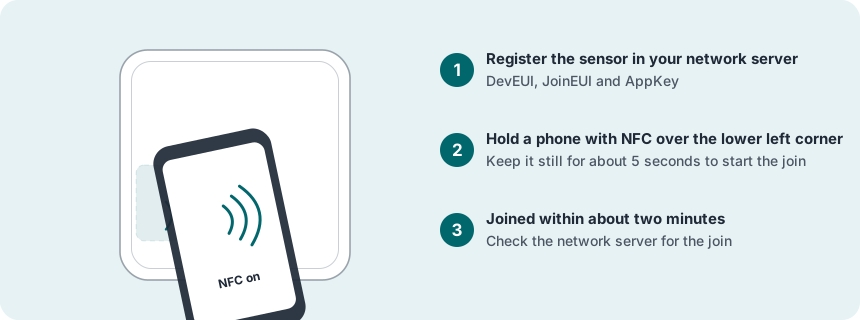
Register the sensor in the network server
- Add a new end device in your network server, with activation OTAA.
- Use these LoRaWAN settings: MAC version 1.0.4, regional parameters RP002-1.0.3, max EIRP 14 dBm, and the frequency plan for your region.
- Enter the DevEUI and the AppKey from the delivery information, and the JoinEUI
70B3D52C0001D4C3. Check them carefully: one wrong character and the join fails. - Set up decoding of the messages (see Decoding the messages).
Join the network with NFC
Hold the phone over the lower left corner of the front of Square Tracker Xtreme and keep it still for about 5 seconds: that starts the join (see Finding the NFC antennas, also for iPhone). The phone may show a web link with the sensor’s serial number; you do not need to open it.
Check the signal where it will sit
Put the sensor at the place where it will be mounted, and look at its messages in the network server: the join, and the first reports.
Configure (optional)
Square Tracker Xtreme comes with the Tracker application. With the default settings it runs a scan train each time it starts or stops moving, and once a day while it is still: Wi-Fi first, and a GNSS scan as the last step if Wi-Fi finds too few access points. GNSS Mode, motion count and motion time are off. Change the settings to fit how often you need positions, and where: every scan costs battery.
How to change them: see Changing the settings, the settings table and the worked examples.
Install
Choose one way, or combine them:
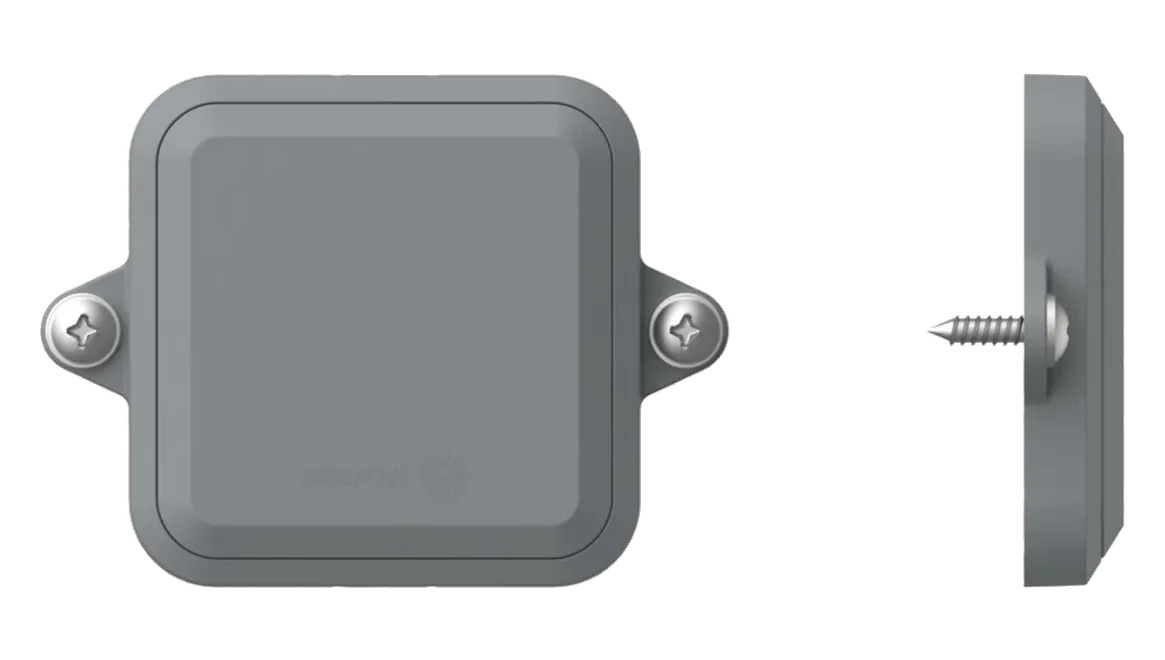
- Screws, with the included mounting frame: fix the frame with M4 screws (not included).
- Adhesive: the adhesive is already on the back. Clean the surface with a 50:50 mixture of isopropyl alcohol and water, so that it is free of dirt and grease, and let it dry. Peel the film off the adhesive and press the tracker firmly in place.
- Cable ties: through the eyelets. Cable ties can be combined with adhesive for extra hold.
Test
Move the asset, or the tracker, and then leave it still. For GNSS, do this outdoors under an open sky.
Ready
- Registered in the network server, with the JoinEUI and the right region
- Joined with NFC, and the messages are decoded
- Signal checked at the final spot: SF9 or better
- Connected to a cloud service that supports GNSS and Wi-Fi positioning, for example Yggio
- Settings checked, or changed as needed
- Mounted on the asset, with the front reachable and, outdoors, a free view of the sky
- Positions arriving when the asset moves
4Using the sensor
The settings named in bold are listed in the settings table.
How Wi-Fi positioning works
- 2.4 GHz only: the radio scans only the 2.4 GHz band (2412–2484 MHz). Networks that broadcast only on 5 GHz are not seen.
- Passive: the sensor listens for nearby Wi-Fi access points (802.11 b/g/n) and records their MAC addresses and signal strength (RSSI). It does not connect to any network, needs no password and sends nothing over Wi-Fi. The addresses travel in the LoRaWAN uplink.
- How many: at least 2 access points are needed for a position, and more give a better one.
- A cloud service is required: to get a position at all, the tracker must be connected to a cloud service that supports GNSS and Wi-Fi positioning, for example Yggio. The service looks the addresses up in a database of mapped access points and returns the position. Munin and LoRa Cloud can also do this.
- Accuracy: depends on how many known access points are around: typically 5–20 m indoors. With only one or two, expect the area rather than the room. Adding low-cost 2.4 GHz access points improves it.
When it scans: the scan train
Each time the sensor starts moving, and each time it stops, it starts a scan train: a series of scans that ends as soon as one of them finds enough access points (the Minimum Wifi Count, 3 by default).
- After 1 minute, a limited Wi-Fi scan, on the channels in the Limited Wifi Scan Channel Mask (all channels by default).
- At the Still Wifi Scan Again At Minute (minute 2 by default), a second limited Wi-Fi scan.
- At the Full Wifi Scan At Minute, a full Wi-Fi scan, on the channels in the Full Wifi Scan Channel Mask (all channels by default).
- At the GNSS Scan At Minute (minute 60 by default), a GNSS scan. The scan train then stops.
- Periodic scans: the scan train is also restarted at the Stationary Scan Interval while the sensor is still (1,440 minutes, once a day, by default) and at the Moving Scan Interval while it moves (off by default). Do not set an interval shorter than the scan train itself.
- Scan budget: each scan uses one unit of a budget. The 15 Minute Scan Budget (3 by default) is added every 15 minutes, up to the Max Scan Budget (100 by default). If the budget runs out during a scan train, the remaining scans wait until it has been topped up.
- Position on demand, with NFC: hold a phone to a sensor that is already joined, as when joining. It starts a scan train at once, and the result arrives as a new scan uplink, which your cloud service turns into a position. This is the way to get a position on demand.
GNSS positioning
- Default, Wi-Fi first: with the default settings (GNSS Mode 0) the tracker positions by Wi-Fi and uses GNSS (GPS and BeiDou) only as the last step of the scan train, when the Wi-Fi scans have found too few access points. Wi-Fi uses less power and works indoors and in built-up areas.
- GNSS Mode: with GNSS Mode on, the scan train starts with a GNSS scan after 1 minute. If it finds the Minimum Satellite Count (3 by default), the result is sent and the train stops. If not, a backup Wi-Fi scan follows at the Fallback WIFI Scan At Minute (off by default), and the train stops.
- Which to choose: for assets that are mostly outdoors, switch GNSS Mode on (GNSS first, with Wi-Fi as backup); for assets that are mostly indoors, keep the Wi-Fi scan train, the default. Worked example 1 shows the switch.
- Sky view: GNSS needs an unobstructed view of the sky. It does not work indoors or under a sheltering roof (see Choosing the place).
- Assisted scans: the tracker records the satellite signals and sends them; the cloud service works out the position. This makes a scan take 3–4 seconds instead of about 30. For good assisted scans the tracker needs the right time, within about 30 seconds, and an up-to-date almanac (the satellites’ orbit data).
- Time and almanac: the tracker asks the network for the time before its Device Time Max Age runs out (see Device registers); once it has, the GNSS scans become autonomous. The application documentation recommends running Munin in the back end to keep the clock in sync and the almanac up to date (see Decoding the messages).
Motion and motion time
- Detecting motion: the accelerometer detects when the sensor moves. The Still Threshold sets how strong a movement must be to count as motion while the sensor is still, and the Moving Threshold while it is moving. If they are set too low, the sensor believes it is always moving and does not start a scan train when it stops. Start from high values and lower them if the sensor is not sensitive enough.
- Motion count: off by default. When it is on, the sensor sends the number of motions detected since it started, once an hour if it has changed.
- Motion time: off by default. When it is on, the sensor sends the total number of minutes in which it has detected movement since it started, once an hour if it has changed.
Temperature
The temperature is measured inside the sensor every 15 minutes, with a typical accuracy of ±2 °C. It is an indication of the conditions around the asset, not a precise room temperature.
- When it has changed by more than the Temperature Hysteresis (2 °C by default) since the last value sent, the sensor sends the new reading.
- Every Average Temp Interval (2 hours by default), it sends the average temperature, if it has changed by more than the same hysteresis.
- Above the Temperature Alarm High Level (60 °C) the alarm state becomes “high”, and below the Temperature Alarm Low Level (2 °C) it becomes “low”. The alarm is sent confirmed, and cancelled when the temperature is back between the levels.
Battery
Once a week the sensor estimates its remaining battery and sends it as a percentage. The estimate is based on the measured running time and the power used by the processor, radio, sensors and position scans.
Network and roaming
- Confirmed messages: the temperature alarm is acknowledged by the network server, and the sensor sends it again if no acknowledgement arrives.
- Rejoining: if the sensor is not joined, it tries to join once every 24 hours. If it was joined and has lost the network, it first makes a few quick join attempts. An NFC touch, as in step 3, starts a join attempt at once.
- Losing the network: the sensor gives the network up if it hears nothing from it for the Downlink Timeout (24 hours by default; see Device registers).
- Roaming: the sensor can be registered in up to 15 LoRaWAN networks, in priority order. Register it in each with the same DevEUI and JoinEUI, and with the last digit of the AppKey counting up:
…00for the first network,…01for the second, and so on. Then set the Roaming Network Count. If the sensor loses its network, it tries the next one in turn. Every 24 hours it goes back to trying the first. More than one network makes each join take longer and use more power.
Decoding the messages
The messages are compact binary records, and their meaning depends on the application version. Decode them with a VSM-aware decoder:
- Yggio decodes them with its built-in VSM translator, and keeps track of each sensor’s application version.
- Other platforms: use Munin, Sensative’s open-source MQTT client. It decodes the messages for any network server, keeps the device state the decoder needs and the device time up to date, and solves Wi-Fi positions.
- Your own integration: the open-source VSM translator is the decoder that Munin uses, available as a Node package. It needs two things from you: it must be able to store at least the rulesCrc32 for each sensor between messages, and it must be kept up to date, since new application versions are released without notice.
Wi-Fi scans arrive on port 23 or 24, and GNSS scans on port 21 (with metadata on port 22); the decoder handles them all.
Changing the settings
There are two ways: over the air, with downlinks from your network server, or on site with the Hugin NFC app. Both usually start in the VSM Configuration Tool, which makes the downlinks for you.
- Pick the application: by name and version, or by the rulesCrc32 from the sensor’s port 15 message (see Which application is in the sensor).
- Choose a configuration: a released profile from the Profile Library (none are released for this application, see Released profiles), or Custom to set your own values. Each setting shows its description, unit and range.
- Take the result: one or more downlinks for port 2, or a single payload for port 7, in hex or base64, to send from your network server. Or a QR code to scan with the Hugin NFC app, which then writes the configuration to the sensor on site.
5The Hugin NFC app
Hugin is an optional Android app for working with the sensor on site, over NFC. It needs an Android phone with NFC and GPS, and an Yggio user account. The sensor must also be registered in Yggio with your organisation as its owner: Hugin checks this with Yggio before it lets you work with the sensor. Hold the phone to the sensor as in Finding the NFC antennas. The app then shows the serial number, the application and its version, the state (for example joined), battery, link and region information, and the DevEUI. Depending on your rights in Yggio, it can read and apply configuration profiles, including one scanned as a QR code from the VSM Configuration Tool, and update the device time and position.
Installation, sign-in, flashing and troubleshooting are in the Hugin NFC app manual.
6Maintenance and removal
Battery
The battery is built in (4,000 mAh) and lasts 10 years at 72 positions a day in a good network (SF7–SF9). Frequent reporting and a weak link shorten it.
Removing Square Tracker Xtreme
Slide dental floss behind the sensor and saw gently through the adhesive.
Moving to another network server
Delete the device from the old network server and add it to the new one. The sensor’s link check then fails, it leaves the old network and joins the new one. This usually takes one to two days. With the Hugin app you can restart it at once instead (Toggle On/Off), but that also resets any custom settings.
Storage and disposal
- Store unused sensors at +10 to +30 °C.
- The sensor contains a non-replaceable lithium manganese dioxide (LiMnO₂) battery, one of the most stable lithium chemistries. Do not open the sensor, and do not puncture it or heat it above +80 °C.
- When the battery is empty, dispose of the whole sensor as a battery, for recycling. Near the end of its life the battery normally swells a little; this is expected.
7Troubleshooting
| Problem | What to do |
|---|---|
| No GNSS position outdoors | GNSS needs an open sky: check that nothing covers the tracker and that its front, top or right side faces the sky. Keep the time and the almanac current (see GNSS positioning). |
| No scan when the asset stops | The Still Threshold or the Moving Threshold is set too low, so the sensor believes it is still moving (see Motion and motion time). Raise them. |
| Scans stop when the asset moves a lot | The scan budget has run out. The remaining scans follow when it has been topped up; raise the 15 Minute Scan Budget only if the battery allows it. |
| No position, or a poor one | A position needs a cloud service that supports GNSS and Wi-Fi positioning, for example Yggio, and enough 2.4 GHz access points that the service knows; networks on 5 GHz only are not seen. See How Wi-Fi positioning works. |
| Nothing happens when I hold the phone to it | Check that NFC is on and the phone case is off. Lay the phone flat against the lower left corner and move it slowly until it signals contact, then hold it still (see Finding the NFC antennas). |
| Join Request in the network server, but no Join Accept | Check the keys, the JoinEUI 70B3D52C0001D4C3, the LoRaWAN version (1.0.4), the regional parameters (RP002-1.0.3) and the frequency plan. In US915 and AU915, the sub-band must match the gateway. |
| Nothing at all in the network server | Check that the gateway is on and online, and that the sensor is in range and not inside a closed metal enclosure. Then start a new join with NFC, as in step 3. |
| “MIC mismatch” | The keys are wrong. Check that they belong to this sensor and are typed correctly. |
| Messages arrive, but the decoder shows no readings | The decoder has usually missed the application identity: send 00 on port 15, and check that the decoder is up to date (see Which application is in the sensor). |
| The Hugin app loses the connection | Hold the phone still until the app has finished (see Finding the NFC antennas). |
| A new setting has no effect | A downlink arrives only after the sensor’s next message, and later on a busy network (see Changing the settings). Check that it is still queued, and that it was made for the rulesCrc32 your sensor reports. |
| Messages missing or irregular | Check RSSI and SNR. The sensor may be too far from the gateway, or shut inside metal. Some channels can also be disturbed by interference on the same frequency band, for example from a nearby cellular transmitter or an RFID reader. |
8Technical reference
For integrators. The values below are for the application Tracker R27–R33. Other versions can differ: check the VSM application documentation or the VSM Configuration Tool for yours.
Which application is in the sensor
Right after it has joined, the sensor sends its application identity, the rulesCrc32, on port 15. The decoder uses it to pick the right translation, and you need it to make the right downlinks. For this application it is:
| Application | Tracker |
| Version | R27–R33 |
| rulesCrc32 | 3802553086 (hex E2A65AFE) |
If you missed the message, send 00 on port 15 and the sensor sends its identity again. The Hugin NFC app also shows the application and its version on site.
Alternative applications: besides Tracker, Sensative can offer other VSM applications for the same hardware. They are available in the Hugin NFC app (Android) and can also be loaded into the sensor over LoRaWAN. Ask Sensative which applications fit your use. After a change, ask for the identity with 00 on port 15 and use the documentation for that application.
LoRaWAN and ports
| LoRaWAN | MAC 1.0.4, regional parameters RP002-1.0.3, class A, OTAA, max EIRP 14 dBm |
| JoinEUI | 70B3D52C0001D4C3 (all Square and Puck sensors) |
| Port | Direction | What it carries |
|---|---|---|
| 1 | Uplink | Temperature, motion count and time, battery (see Messages) |
| 11 | Uplink | The same outputs in compressed form |
| 15 | Uplink | Application identity (rulesCrc32), first thing after a join |
| 15 | Downlink | 00 asks the sensor to send its application identity again |
| 23, 24 | Uplink | Wi-Fi scans, for positioning. They arrive on port 23 or 24; the decoder handles both. |
| 21 | Uplink | GNSS scans, for positioning |
| 22 | Uplink | GNSS scan metadata |
| 2 | Downlink | Settings and read requests (see Settings on port 2) |
| 2 | Uplink | The sensor’s answer: the values it now has |
| 7 | Downlink | A whole configuration in one payload (see A whole configuration on port 7) |
| 7 | Uplink | The status of that configuration: None, Applied, Error or Dirty |
Messages
Each output has an id and a scale. “Confirmed” outputs are acknowledged by the network server.
| Output | Id | Size and scale | Unit | Confirmed | Sent |
|---|---|---|---|---|---|
| temp | B0 | 2 bytes, × 0.01 | °C | No | On a change larger than the Temperature Hysteresis (measured every 15 minutes) |
| averageTemp | B1 | 2 bytes, × 0.01 | °C | No | Every Average Temp Interval, if changed by more than the Temperature Hysteresis |
| tempAlarm | 80 | 1 byte | 0 = no alarm, 1 = high, −1 = low | Yes | When the alarm state changes |
| motionCount | BA | 4 bytes | number of motions since start | No | Hourly if changed, when Enable Motion Count Report is on |
| motionTimeMinutes | BB | 4 bytes | minutes with motion since start | No | Hourly if changed, when Motion Time Enabled is on |
| batteryPercent | AE | 1 byte | % (estimated) | No | Once a week |
Settings
The defaults are the values the sensor starts with. The id is what a port 2 downlink uses. Values are sent in the steps shown: the temperature hysteresis, in steps of 0.01, is sent as a hundred times its value; all the others are whole numbers.
| Setting | Name in the application | Id | What it does | Unit | Range | Default |
|---|---|---|---|---|---|---|
| Still Threshold | stillMotionThreshold_mm_s2 | B3 | How strong a movement must be to count as motion while the sensor is still. Too low, and it believes it is always moving. | mm/s² | 5–10,000 | 50 |
| Moving Threshold | movingMotionThreshold_mm_s2 | B4 | How strong a movement must be to count as continued motion while the sensor is moving. | mm/s² | 5–10,000 | 30 |
| Minimum Wifi Count | minimumWifiCount | A6 | How many Wi-Fi access points a scan must find for the scan train to stop. | access points | 1–15 | 3 |
| Still Wifi Scan Again At Minute | singleWifiScanAgain_minutes | A5 | Minute of the second limited Wi-Fi scan after the sensor starts or stops moving. −1 switches it off. Avoid 1: the first scan is always at minute 1. | minutes | −1 to 127 | 2 |
| Full Wifi Scan At Minute | fullWifiScan_minutes | A8 | Minute of the full Wi-Fi scan after the sensor starts or stops moving. −1 switches it off. Avoid 1. | minutes | −1 to 127 | not documented |
| Limited Wifi Scan Channel Mask | limitedScanChannels | B8 | The Wi-Fi channels for the limited scans, as a bit mask: channels 1 and 3 are binary 101, decimal 5. 0 means all channels. Fewer channels save power. | bit mask | 0–65,535 | 0 |
| Full Wifi Scan Channel Mask | fullScanChannels | B9 | The Wi-Fi channels for the full scan, as a bit mask in the same way. | bit mask | 0–65,535 | 0 |
| GNSS Mode | gnssMode | AC | 1 starts each scan train with a GNSS scan, with an optional Wi-Fi backup. 0 is Wi-Fi first, with GNSS as the last step. | on/off | 0–1 | 0 |
| GNSS Scan At Minute | gpsScan_minutes | A9 | Minute of the GNSS scan, the last step of the scan train when GNSS Mode is off. −1 switches it off. Avoid 1, and avoid the same minute as the full Wi-Fi scan. | minutes | −1 to 127 | 60 |
| Minimum Satellite Count | minimumGnssCount | A7 | In GNSS Mode: how many satellites a GNSS scan must find for the scan train to stop. | satellites | 1–15 | 3 |
| Fallback WIFI Scan At Minute | backUpWifiGnssScanMinutes | AD | In GNSS Mode: minute of the backup Wi-Fi scan, if the GNSS scan did not find enough satellites. −1 switches it off. Do not set it before minute 1. | minutes | −1 to 127 | −1 (off) |
| Moving Scan Interval | movingScanIntervalMinutes | BC | Restarts the scan train at this interval while the sensor is moving. −1 switches it off. Do not set it shorter than the scan train. | minutes | −1 to 32,768 | −1 (off) |
| Stationary Scan Interval | stationaryScanIntervalMinutes | BD | Restarts the scan train at this interval while the sensor is still. −1 switches it off. | minutes | −1 to 32,767 | 1,440 |
| 15 Minute Scan Budget | quarterlyScanBudget | A4 | How many scans are added to the scan budget every 15 minutes. | scans | 1–15 | 3 |
| Max Scan Budget | maxBudget | B5 | The most the scan budget can hold. Each scan uses one unit. | scans | 1–32,767 | 100 |
| Enable Motion Count Report | motionCountEnabled | AA | 1 sends the number of motions detected, hourly if changed. | on/off | 0–1 | 0 |
| Motion Time Enabled | motionTimeEnabled | AB | 1 sends the number of minutes with motion, hourly if changed. | on/off | 0–1 | 0 |
| Temperature Hysteresis | tempHysteresis | B2 | Change in temperature needed before a new reading or average is sent. | °C, steps of 0.01 | 0.1–127 | 2 |
| Average Temp Interval | averageTempIntervalHours | A0 | How often the average temperature is sent, if it has changed by more than the hysteresis. | hours | 1–127 | 2 |
| Temperature Alarm Low Level | tempAlarmLowLevel | A1 | Low alarm level. Must be below the high level, or the alarm is off. | °C | −128 to +126 | 2 |
| Temperature Alarm High Level | tempAlarmHighLevel | A2 | High alarm level. Must be above the low level, or the alarm is off. | °C | −127 to +127 | 60 |
| Roaming Network Count | roamNetworkCount | A3 | Number of LoRaWAN network identities to try in turn (see Network and roaming). | number | 1–15 | 1 |
| Quick Rejoin Attempts | quickRejoinBudgetMax | B6 | How many quick join attempts the sensor makes after losing a network, before it goes back to one attempt a day. | number | not documented | not documented |
Device registers
These belong to the sensor’s firmware rather than to the application, but the application uses them and they can be changed the same way. Leave them as they are unless you have a reason.
| Register | Name | Id | What it does | Unit | Range | Default |
|---|---|---|---|---|---|---|
| Downlink Timeout | LINKCHECK_TIME | D0 | How long the sensor goes without hearing from the network before it gives the network up and becomes unjoined. Any downlink, an acknowledgement included, starts the time again. From half the time on, every uplink is sent confirmed; from 80 % on, the sensor also sends link checks of its own. 0 turns the check off. The sensor sets it back to 24 hours each time it starts. | seconds | 300–2,592,000 | 86,400 |
| TX Power Range | TX_POWER_RANGE | D8 | The power index range for fast adaptive data rate: lowest in the low byte, highest in the high byte, each 0 (the region’s best) to 16 (DR0, maximum power). Raising it costs a lot of battery. | 2 bytes | 0–65,535 | |
| Device Time Max Age | GPS_TIME_MAX_AGE | CD | How long the sensor trusts its clock. Once this time has passed, the GNSS scans become autonomous (no longer assisted). From 80 % of it, the sensor asks the LoRaWAN network for the time with the standard DeviceTime request (DeviceTimeReq, LoRaWAN 1.0.3 and later); the network server must answer DeviceTime requests. The clock typically drifts a few seconds a day, more outdoors. | seconds | 0–4,294,967,295 | 0 |
Released profiles
No ready-made profiles are released for this application. The sensor starts with the defaults in the settings table; to change them, use Custom in the VSM Configuration Tool.
Settings on port 2
A port 2 downlink is a list of records of 5 bytes each: one byte for the setting’s id, then the value as a signed 32-bit integer, most significant byte first. The value is in the setting’s own steps: a temperature hysteresis of 2 °C in steps of 0.01 is sent as 200; a scan interval of 30 minutes is sent as 30. Negative values are written in two’s complement, so −10 becomes FF FF FF F6. The sensor applies the values and answers on port 2 with the values it now has.
Reading values
A port 2 downlink of one to four bytes is a read request: the sensor sends back the current value of each id in it.
| Port 2 downlink | The sensor answers with |
|---|---|
04 | Current temperature, in hundredths of a degree |
16 | The motion sensor |
BD | The Stationary Scan Interval now set (any setting id works the same way) |
A whole configuration on port 7
The VSM Configuration Tool can also pack a configuration into a single port 7 payload. It starts with the application’s CRC and ends with a checksum of the configuration (configCrc32). The sensor reports the result on port 7: None, Applied, Error or Dirty.
Worked example 1: GNSS first, for assets that are mostly outdoors
Switch GNSS Mode on, with a backup Wi-Fi scan at minute 5 if the GNSS scan finds too few satellites. Both examples were made in the VSM Configuration Tool for rulesCrc32 3802553086. Send one of the payloads, port 2 or port 7, not both.
| Setting | Value | Sent as | Record |
|---|---|---|---|
| GNSS Mode | on | 1 | AC 00 00 00 01 |
| Fallback WIFI Scan At Minute | 5 | 5 | AD 00 00 00 05 |
| Port 2 (hex) | AD 00 00 00 05 AC 00 00 00 01 |
| Port 2 (base64) | rQAAAAWsAAAAAQ== |
| Or port 7 (hex) | E2 A6 5A FE 02 0A AD 00 00 00 05 AC 00 00 00 01 00 3F 74 C4 7F |
Worked example 2: Positions while the asset is moving
Restart the scan train every 30 minutes while the sensor is moving. Each restart uses scans from the budget and battery.
| Setting | Value | Sent as | Record |
|---|---|---|---|
| Moving Scan Interval | 30 min | 30 | BC 00 00 00 1E |
| Port 2 (hex) | BC 00 00 00 1E |
| Port 2 (base64) | vAAAAB4= |
| Or port 7 (hex) | E2 A6 5A FE 02 05 BC 00 00 00 1E 00 55 6F 44 60 |
9Specifications
| Positioning | GNSS (GPS and BeiDou) outdoors, 2.4 GHz Wi-Fi scanning indoors; a cloud service that supports both is needed |
| Sensors | Motion (3D accelerometer), temperature (typical ±2 °C) |
| Radio | LoRaWAN 1.0.4, class A, OTAA; JoinEUI 70B3D52C0001D4C3 |
| Frequency plans | EU868 · US915 · AU915 · AS923-1 · AS923-2 · KR920 · IN865 |
| Range | Up to 10 km in line of sight |
| Configuration | NFC (Android) and over the air |
| Application | VSM application Tracker (R27–R33) |
| Battery | Built-in LiMnO₂, 4,000 mAh; 10 years at 72 positions a day |
| IP rating | IP68 |
| Impact rating | IK06 |
| Operating temperature | −20 to +60 °C |
| Dimensions | 67.2 × 60.4 × 13 mm |
| Weight | 61 g |
| Mounting | Screw frame included; adhesive or cable ties through the eyelets also work |
10Support
- VSM Configuration Tool, opened at this application: vsm-lora-config-app.service.sensative.net
- VSM application documentation for this version: github.com/Sensative/vsm-application-documentation
- Munin MQTT client and decoder (open source): github.com/Sensative/vsm-mqtt-client-open-source
- VSM translator (open source): github.com/Sensative/vsm-translator-open-source
- Hugin NFC app: Sensative Docs
- Support, FAQ and downloads: sensative.com/support
- Product page and product sheet: sensative.com/sensors/square-tracker-xtreme
Sources: Sensative Docs, Square Tracker Xtreme (Dec 2024, including the GNSS scan times), FAQ Square & Puck and Hugin NFC application; VSM Configuration Tool, application data for Tracker (read 31 October 2026); VSM application documentation on GitHub (3802553086-Tracker); VSM translator (open source); specifications from the sensative.com product data; Wi-Fi positioning: Semtech, Wi-Fi geolocation with LoRa Edge.